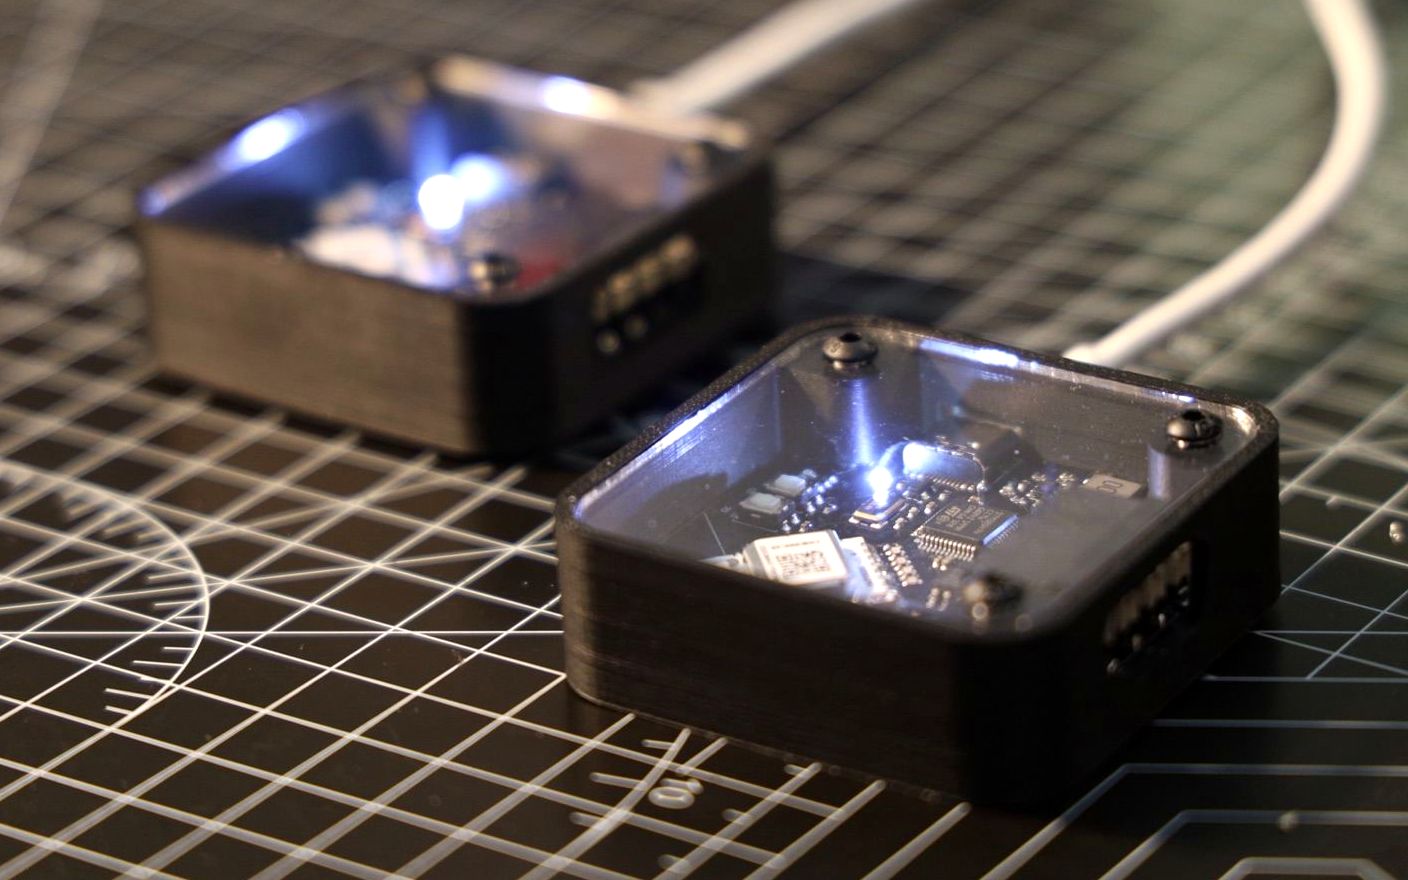
U1 Distance Kit
Two tags.
Live distance over USB or ROS 2.
Free U.S. shipping
UWB distance and indoor positioning for robots, with USB-C and ROS 2.
Kits
U1 Distance Kit
Live distance over USB or ROS 2.
Free U.S. shipping
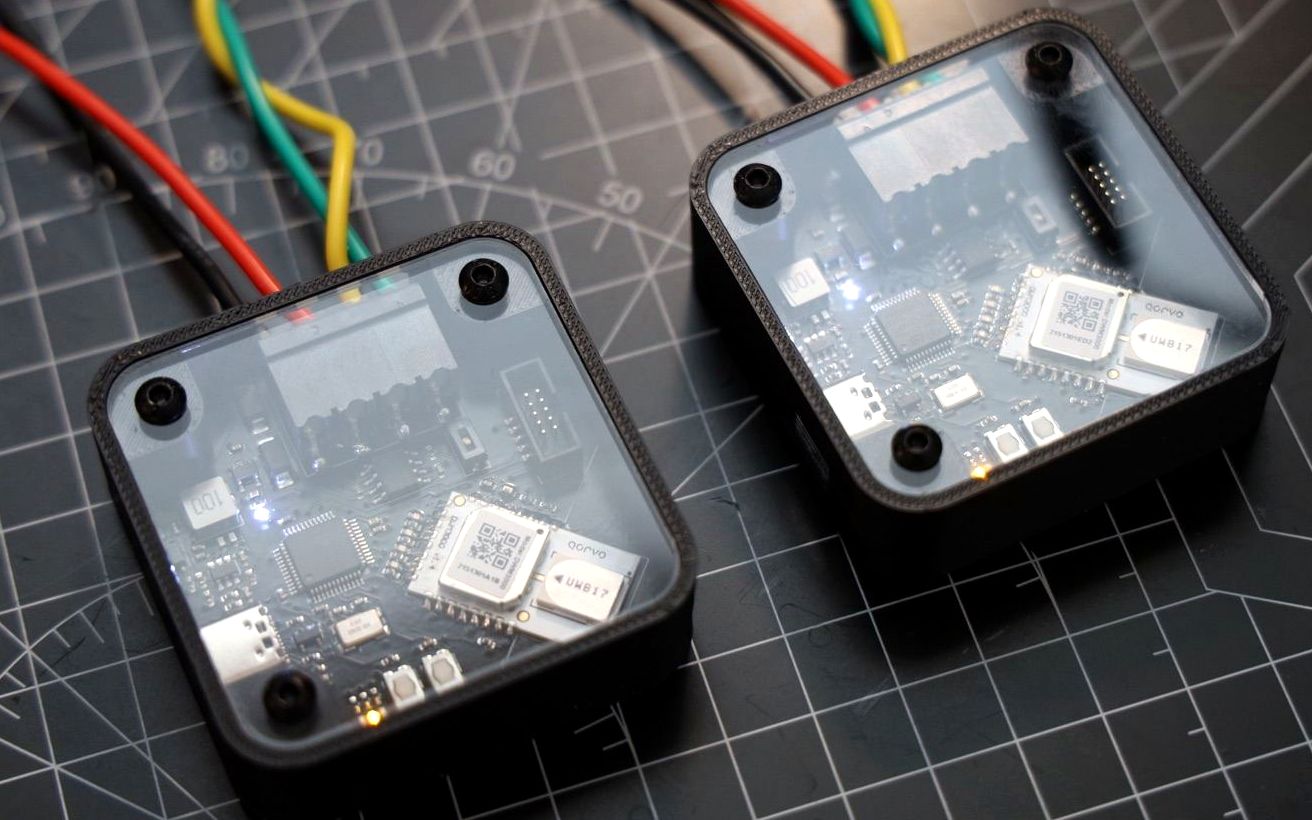
U1 Location Kit
2D or 3D position in a room. Requires an anchor survey and calibration.
Free U.S. shipping
How it works · illustration
Hardware
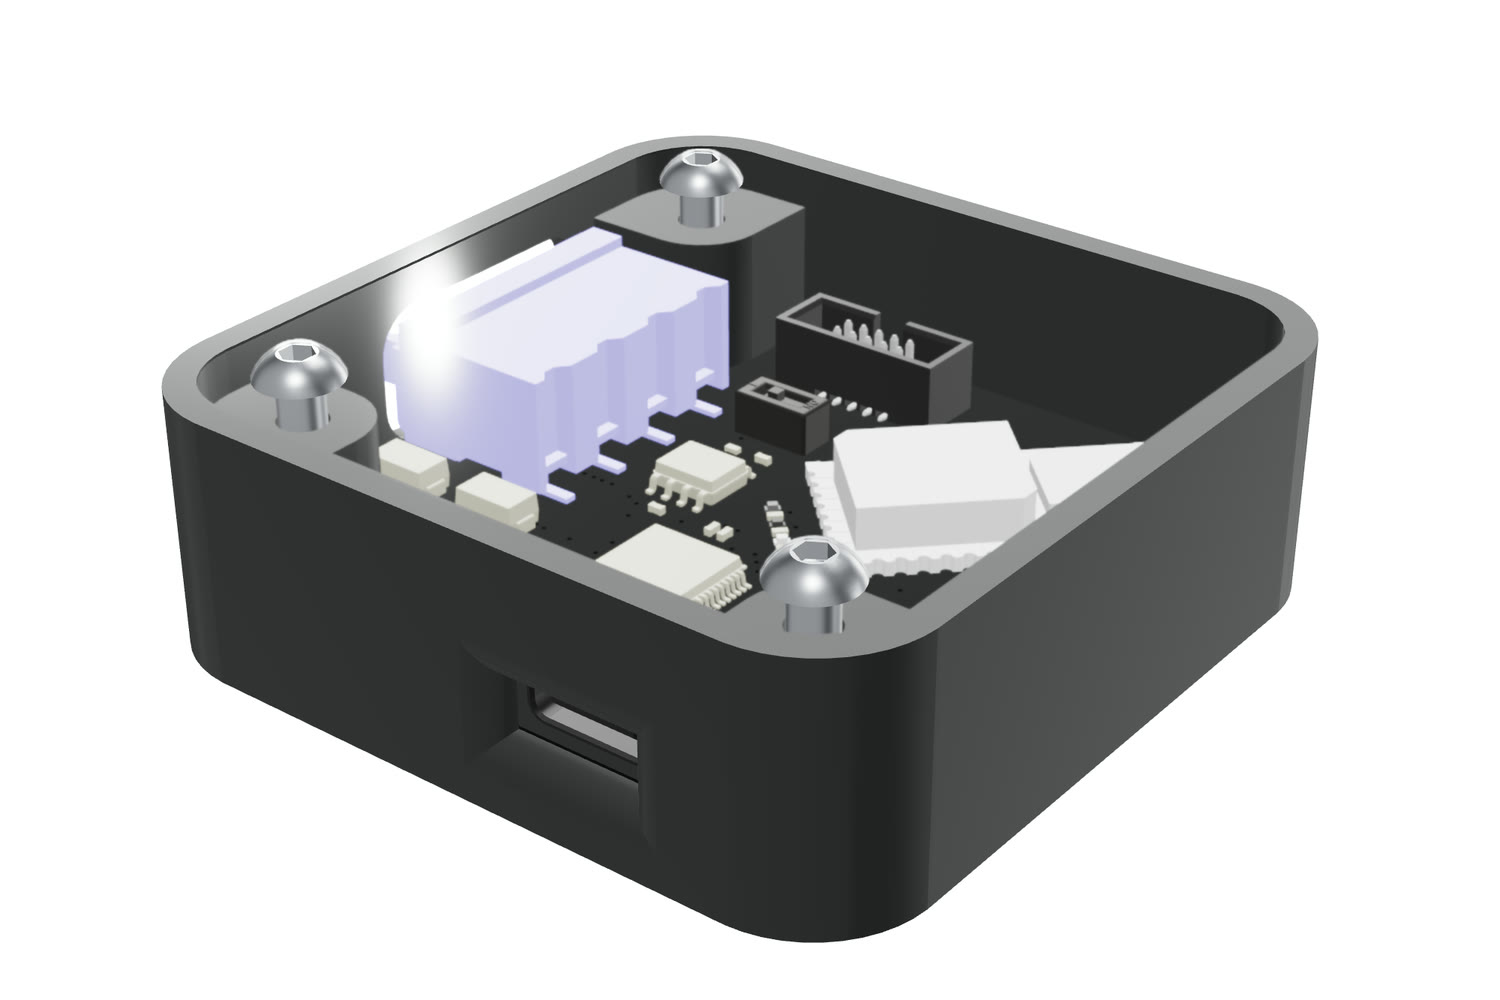
Mechanical
PETG case, clear acrylic lid and M3 mounting, about 5.4 × 5.4 × 1.8 cm.
Loading 3D assembly
Drag to rotate · scroll to zoom
Resources
Open source under the MIT License: schematics, PCB, firmware, CAD and tools are on GitHub.